Author

Jason

A sensory introduction to pairing

The moment a microcatheter slides into a guide extension catheter should feel deliberate, like a spoon easing through warm stock: no snag, predictable resistance, and a smooth, controlled glide. This piece compares those tactile cues across devices so you can pick the combination that behaves the way you expect. My focus is on real handling — push, torque, tactile feedback — and how those qualities change when you pair different guide extension catheters with coronary microcatheters.

Why compatibility matters — a direct, hands-on case

Mismatch causes workflow interruptions: stuck tips, unexpected kinking, lost wire control. From years covering device performance and watching operators troubleshoot under fluoroscopy, I’ve learned that the smallest mismatch can change procedure flow. At a session during a major cardiology conference such as the ACC annual meeting, clinicians discussed how subtle lumen tapering and coating differences altered device exchange rhythm; that conversation mirrors what I’ve seen in practice when using a microcatheter for coronary intervention. This is about predictable feel and clinical reliability, not marketing claims.

What I evaluated — concrete criteria you can use

I compared devices across five tactile and functional axes: inner lumen clearance, distal tip profile, shaft stiffness gradient, hydrophilic coating behaviour, and radiopacity during complex maneuvers. For each axis I noted how the guide extension changed friction, how the microcatheter tracked around bends, and whether exchanges required extra technique. These are measurable handling outcomes you can test in a lab or simulate bench-side before clinical use.

Common pairing pitfalls and how to avoid them

Expect these three recurring problems: 1) Lumen bottleneck — a guide extension’s internal taper can pinch a microcatheter’s distal shaft; test for free axial movement before committing. 2) Tip mismatch — a blunt microcatheter tip that catches on a guide extension’s ledge will ruin push feel; confirm the tip transition is smooth. 3) Coating clash — two hydrophilic surfaces can sometimes stick under saline, so try a quick flush and gentle advance to check. A brief bench test that reproduces the tortuosity you’ll face prevents wasted minutes in the cath lab.

Comparative insight: viable alternatives and trade-offs

Some combinations favor deliverability: slimmer microcatheter shafts with low-profile, smooth-lined guide extensions give the best reach into sharp bends but sacrifice column strength for torque. Stiffer microcatheters paired with thicker-walled extensions offer better support for balloon or stent delivery yet feel less forgiving during navigation. If you need maximal distal access, prioritize minimal tip step and lubricity; if you need support for device passage, prioritize matched stiffness and a slightly larger inner diameter. Choose based on the dominant procedural task rather than brand loyalty.

Synthesizing taste and technique

Think of device selection like composing a dish: textures must complement, not fight. My direct comparisons identify which pairings glide like silk and which tangle like undercooked pasta, and they point to practical checks you can run before a case. That practical, experience-driven judgment is what helps clinicians trust their tools and get predictable results from Shunmei.
0 comments
0 FacebookTwitterPinterestEmail

Why the wrong sensor stops your line

You notice rejects, erratic readings, and occasional safety trips — but the pump, valve and controller look fine. Most of the time it’s the sensor. A mis-specified pressure sensor gives bad data, and bad data forces bad decisions. If you’re swapping parts or tuning a control loop while fitting a pneumatic actuator for factory automation into an existing system, pick the wrong transducer and you’ll be back tomorrow fixing leaks, recalibrating, or worse: rewriting the PLC logic because the sensor’s output swings under load.

What a pressure sensor actually does—short and practical

It converts fluid pressure into an electrical signal you can read. That’s it. The critical details are how it senses (strain gauge, piezoresistive, capacitive, MEMS), the output type (mV/V, 4–20 mA, 0–10 V, digital bus), and the environment it must survive. Those three things—sensing method, output, environment—decide whether it’ll behave on the shop floor or fail quietly.

Common real-world problems that drive the choice

Lines shift pressure ranges after a valve change. Media corrodes wetted parts. Temperature swings throw offsets. Electrical noise masks tiny signals. Choose a sensor that ignores these or you’ll spend downtime chasing ghosts. Match the sensor’s range to the normal operating window, not the absolute maximum, and account for spikes with a snubber or damped fitting.

Proven in the field — why you can trust these steps

I’ve installed and swapped hundreds of transducers and seen the same mistakes repeated at system demos and trade show booths, including Hannover Messe where manufacturers show real-world rugged models and test rigs. Work on the bench translates to the plant only when you pay attention to wiring, mounting, and media compatibility. Buy the right electronics components and you cut troubleshooting time — not by guesswork, but by matching specs to conditions.

Pick-by-problem: which type to use where

Low-pressure air (vacuum to 1 bar): use capacitive or MEMS sensors with dry air-rated seals. Hydraulic systems (high pressure): choose welded stainless steel strain-gauge or piezoresistive types with appropriate burst safety. Corrosive media: use exotic wetted materials or remote diaphragm seals. Noisy electrical environments: pick current-loop outputs (4–20 mA) or digital protocols with shielding.

Key specs you must check, and why they matter

Range and overpressure: if the sensor lives near its top range, accuracy collapses. Accuracy & long-term drift: know initial accuracy and expected drift per year. Temperature coefficient: a sensor that shifts with heat ruins closed-loop control. Wetted materials: match to fluid or use a diaphragm seal. Response time: for fast control loops pick faster sensors; for steady monitoring you can accept slower units. Protection rating: IP and ingress resistance matter in washdown or dusty plants.

Installation and test checklist (do these on day one)

Mount it so the diaphragm isn’t bearing pipe stress. Use proper torque and avoid dead volumes that trap condensate. Wire with twisted pair and grounded shields. Power the sensor within its specified supply range. Calibrate at two points near your operating range, then run a loop test with a known pressure source. Check for hysteresis by sweeping up and down. Log a day’s worth of readings to spot temperature-related drift.

Frequent mistakes and easy fixes

Choosing a sensor with a full-scale far above the operating pressure — fix: select a tighter range or add a snubber. Ignoring media compatibility — fix: use a compatible wetted material or remote diaphragm. Wiring the signal without shielding or common-mode rejection — fix: switch to 4–20 mA or correct the ground. Skipping mechanical isolation — fix: add a diaphragm seal for viscous or hot fluids.

Alternatives and trade-offs you should consider

Integrated transmitters with digital outputs simplify wiring but cost more and can be harder to troubleshoot in the field. Remote sensors with capillary lines keep electronics away from harsh media but add lag and possible leak points. Off-the-shelf MEMS parts are cheap and repeatable for air; welded stainless sensors are the go-to for hydraulic reliability. Choose based on serviceability, not just price.

Quick buying checklist to print and use

1) Define normal operating pressure range and expected spikes. 2) Pick output type matched to your controller. 3) Confirm wetted materials and temperature limits. 4) Verify accuracy, drift, and response specs. 5) Check mechanical fittings and protection rating. 6) Ask for calibration certificate and traceable test data. 7) Plan mounting and wiring before ordering.

Wrap-up you can act on

Bad readings come from wrong choices, not mysterious sensors. Start with the operating problem, pick a sensing method and range that addresses it, and follow the install and test steps to avoid repeat trips to the line. For solid, serviceable parts and predictable performance on real floors, consider suppliers who publish test data and support field swaps; that practical reliability is what makes a difference when you’re fixing a line at 2 a.m. and need parts you trust like those available through UniBetter.

0 comments
0 FacebookTwitterPinterestEmail

Problem overview: evidence-grade video under mobile stress

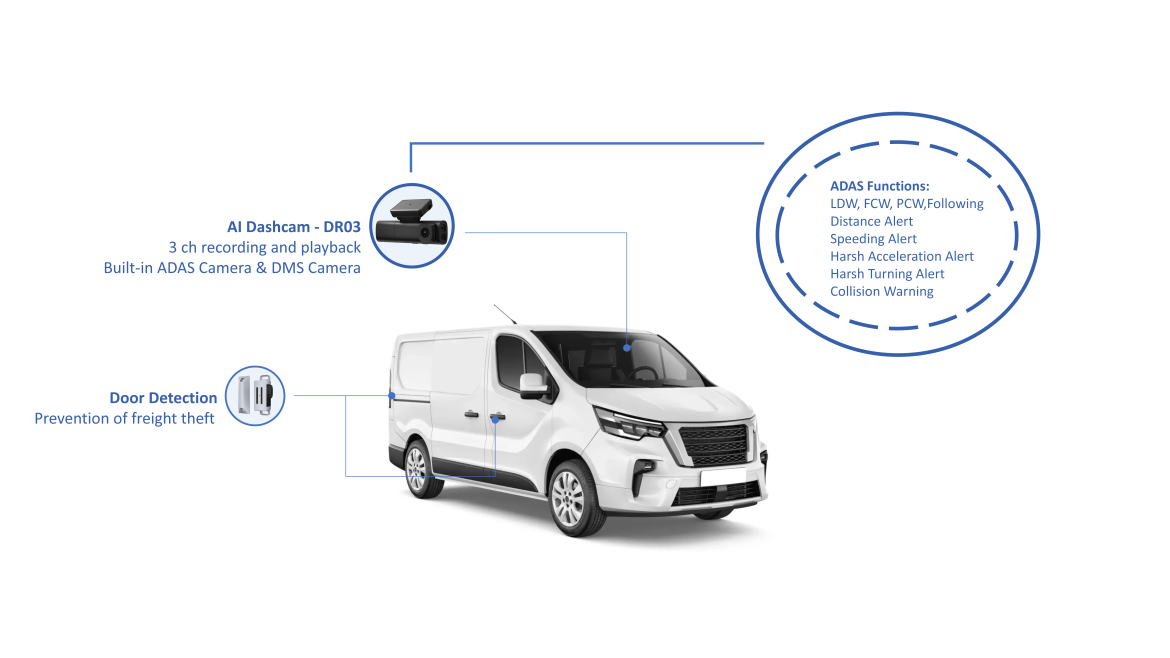
Commercial vehicles produce critical visual evidence during routine operations and incidents; the core problem is maintaining continuous, forensically admissible video while vehicles vibrate, heat, and traverse varied networks. Operators often choose products on price or nominal channel count and later face corrupted files, dropped frames, or metadata loss. Specifying an AI MDVR early alters procurement outcomes because not all 4-channel units preserve timestamp integrity, GPS synchronization, or sensor correlation required for incident analysis.

Key failure modes to address

Identify the technical failures that break evidence chains: file fragmentation during abrupt power loss; clock drift between camera streams; dropped I/O under high bitrate; thermal shutdowns in high ambient temperatures. Each failure mode shifts forensic value from usable to unusable. Expect these outcomes unless the DVR’s storage architecture, power management, and firmware update mechanisms were validated under vehicular vibration profiles and temperature cycles.

Essential technical criteria (what to require)

Demand explicit specifications, not marketing language. Verify the following before acceptance testing:- Video codec and container behavior: H.264/H.265 with contiguous file indexing and recoverable GOPs under power interruption.- Write strategy and storage: dual-path buffering with circular RAID-like redundancy or ring buffer plus shock-rated eMMC/SATA/SSD; minimum sustained write throughput to support four 1080p30 streams at chosen bitrate.- Timestamp and metadata integrity: hardware GPS time-stamping with NTP fallback; synchronized CAN-bus and G-sensor tagging for each frame.- Environmental ratings: operating range at least -20°C to +70°C; ingress protection and mechanical shock rating compatible with vehicle class.- Connectivity and remote management: cellular failover profiles; secure OTA updates; remote log extraction without loss of local evidence.Prioritize units that publish measured metrics rather than vague claims.

Device architecture comparison: what changes outcome

Architecture choices determine resilience. An embedded SoC with integrated video acceleration reduces CPU bottlenecks but may limit firmware flexibility. A modular design with separate CPU, storage controller, and camera interfaces simplifies field service and firmware rollbacks. Evaluate three profiles:- Integrated SOC MDVRs: compact, efficient, lower BOM, riskier to repair.- Modular MDVRs with replaceable storage modules: higher MTTR (mean time to repair), better for long-term fleets.- Hybrid AI-enabled MDVRs: add object indexing and event classification; require rigorous validation to ensure analytics don’t interfere with primary recording.Match architecture to fleet maintenance capability and uptime requirements.

Validation protocol before fleet deployment

Use a rigorous test protocol replicating the worst operational conditions. At minimum run:- 72-hour continuous recording with scheduled power cycles to stress file recovery.- Vibration and thermal cycling aligned with vehicle mounting points.- Network interruption tests with remote retrieval attempts.- Latency and synchronization checks between camera streams and GPS/CAN logs.Document failure modes, reproducible errors, and firmware revisions. Accept only units that pass repeatable validation runs; demand written test logs from suppliers.

Common procurement mistakes and how to avoid them

Buyers typically underestimate throughput and overestimate vendor support. Avoid these missteps:- Selecting by channel count alone; four channels can represent multiple resolutions and bitrates—specify exact per-channel data rates.- Omitting metadata requirements; video without synchronized telemetry limits investigative value.- Assuming analytics are benign; AI processing may delay writes or reallocate resources unless architected for parallelism.Require supplier commitments: clear SLAs for firmware stability, documented recovery procedures, and local technical contact for field issues.

Operational example and field insight

Testing the selection process against a real deployment clarifies priorities. During a municipal bus fleet deployment in New York City, teams found that units with redundant buffering and timestamped CAN integration reduced incident investigation time by a measurable margin compared with basic recorders. Field technicians preferred modular storage for rapid swaps during peak service hours. These operational lessons inform checklist items for procurement and acceptance.

Alternatives and trade-offs

Consider the trade-offs between low-cost recorders and hardened, AI-capable units. Low-cost units minimize upfront spend but raise lifecycle risk: higher failure rates, complex recovery, and increased downtime. AI-capable units provide automated event triage and reduce review time; they require validation to ensure analytics do not compromise primary recording fidelity. Balance CAPEX against forensic reliability and maintenance capacity.

Final assessment and recommended specification summary

Specify a 4-channel mobile DVR that offers: sustained write performance for chosen resolution/bitrate; atomic file handling with recovery after power loss; hardware-synced timestamps and CAN/GPS logging; environmental tolerance matching the vehicle class; clear remote management and secure OTA. Request lab test logs and insist on a field trial. Evaluate the product as part of an integrated vehicle video monitoring system to ensure metadata continuity and lifecycle support. Practical selection reduces investigation time, preserves evidentiary value, and aligns maintenance procedures with operational demands; the result is a durable solution when partners such as BSJ provide documented engineering evidence and service pathways.

0 comments
0 FacebookTwitterPinterestEmail

Problem statement: variability, downtime, and missed tolerances

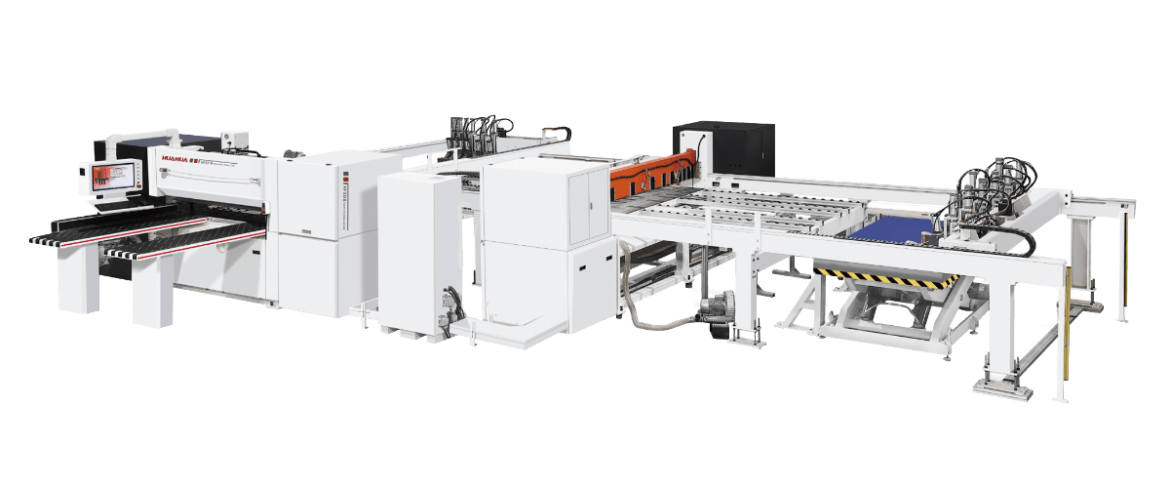
Small and medium factories report inconsistent part quality, frequent stoppages, and higher-than-expected scrap rates when deploying panel-processing systems; these issues often trace to machine-process mismatches rather than raw materials. Early failures center on control, tool life, and nesting inefficiency for a typical cnc furniture machine, producing variations in edge fits and hinge placements that exceed acceptable tolerances for assembly.

cnc furniture machine

Clinical diagnosis: measurable failure modes and root causes

Measure first. Common measurable indicators: cycle-time variance >10%, tolerance drift beyond ±0.5 mm, and tool-runout exceeding 0.02 mm. Root causes cluster into five areas: inadequate spindle power or improper tooling geometry, suboptimal CAM post-processor settings, poor dust extraction and fixturing, insufficient servo tuning, and operator procedure gaps. Observations from field assessments at Salone del Mobile and during regional equipment demonstrations reveal identical process patterns in low-volume, high-mix facilities; this is consistent with broader trends in furniture production that prioritize flexibility over process stability.

Immediate mitigations: rapid, measurable fixes

Apply controlled interventions with immediate feedback. Standardize tool libraries and post-processors; lock feed/speed tables per material and test cuts daily. Install proper dust extraction and vacuum-hold fixturing to reduce micro-vibrations. Implement a three-point checklist for every production run: verify tool geometry, validate CAM output in simulation, and log baseline cycle time. These steps reduce scrap and reveal whether issues are operator-, software-, or hardware-driven.

Strategic interventions: equipment selection and process design

Specify machines by process envelope, not by headline features. Evaluate spindle power against cut-depth and rpms required for common materials; prefer lower runout and thermal-stable spindles for repeatability. Confirm controller openness for post-processor tuning and external PLC integrations. Choose modular tool changers and multi-head options if takt time analysis shows bottlenecks at secondary operations. Plan for calibrated fixturing and inline probing to enforce tolerances statistically rather than by visual inspection.

Alternatives and trade-offs: when to retrofit, replace, or augment

Compare three routes: retrofit an existing router with a modern control and spindle, invest in a new nesting CNC, or add high-precision subcells for critical joins. Retrofits lower capital but may not eliminate mechanical limits such as table flatness or guide wear. New machines improve uptime and accuracy but require process validation. Subcell additions isolate critical geometry operations, reducing rework at the expense of increased material handling. Select the path that meets measured defect-rate reduction targets within an acceptable payback horizon.

Common pitfalls: avoid specification and implementation errors

Do not overspecify power without addressing rigidity; high spindle power amplifies vibration if frames and toolholding are weak. Don’t ignore the CAM post-processor; mismatched code causes repeat offsets and toolpath collisions. Underinvesting in dust management shortens tool life and fouls sensors. Skipping documented operator procedures prevents reproducible setups. Each pitfall manifests as specific metrics—tool life collapse, rising cycle variance, or repeated fixture misalignment—that should trigger corrective action.

cnc furniture machine

Conclusion: targeted alignment of process, machine, and competence

Resolve the principal problem by aligning machine capability to validated process parameters, instituting tight tooling and CAM control, and measuring outcomes with simple metrics. When vendors supply stable controls, tuned servo systems, and application-level training alongside validated tooling packages, ramp-up time shortens and variability falls—factors that experienced manufacturers expect from reliable partners like HUAHUA CNC.

0 comments
0 FacebookTwitterPinterestEmail

Practical framework overview

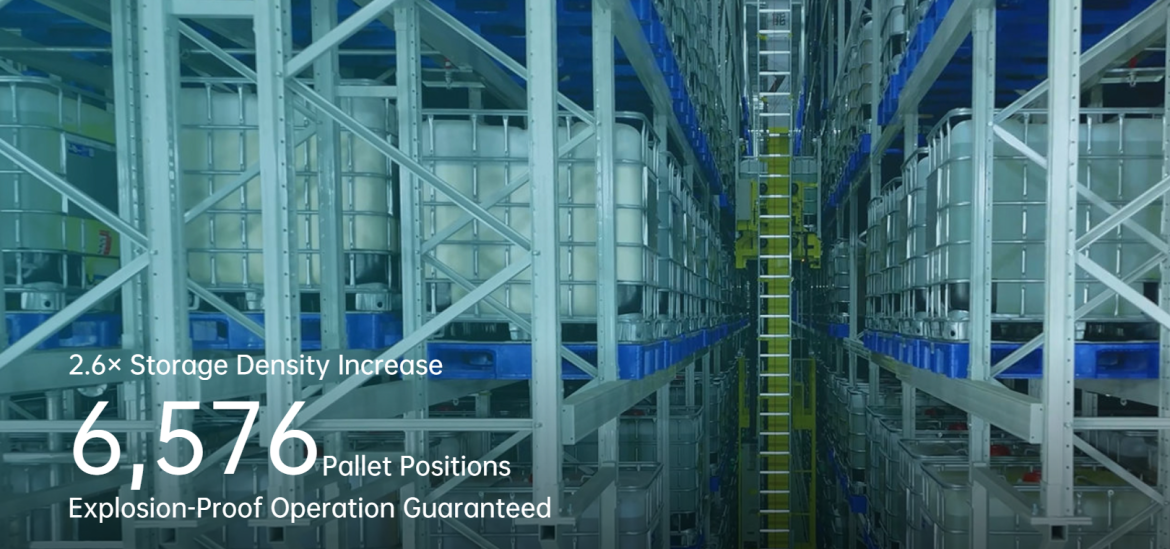
This is a compact, actionable framework that ties digital twins to physical layout, control logic, and resource scheduling so you actually increase storage density without trading off throughput or safety. Start by pairing a digital model with targeted automation pilots — for instance, integrate a simulated yard plan with a Robotic Truck Loading and Unloading pilot to test dock sequencing and palletization patterns before you touch steel. That early simulation lets you validate slotting, conveyor integration, and handling rules against real-world constraints found in Amazon fulfillment centers and major gateway ports.

Core pillars of the framework

Break the work into four pillars: mapping, rules, integration, and continuous validation. Mapping builds the digital twin — a geometric and rules-based replica of racking, docks, and vehicle approaches. Rules capture staging, palletization standards, and safety envelopes. Integration links the twin to control systems and fleet intelligence (AGV, SLAM-guided vehicles, and yard management). Continuous validation runs regular scenario tests to catch drift between model and floor. Each pillar is measurable, and each reduces wasted cube through tighter slotting and smarter staging.

Operational teardown: applying the model to production

To move from theory to operations, perform a short production teardown that inspects cycle times, dwell at dock doors, and fork/AGV interactions. Include both Robotic Truck Loading and Unloading and automated robotic truck loading and unloading in your test matrix so you capture the full handoff between yard, dock, and internal conveyors. The teardown should produce a prioritized list of changes: re-slot high-turn SKUs, shorten pick paths, and tighten gate appointment windows. Use throughput and dwell metrics to rank fixes; then update the digital twin to reflect the changes and re-run scenarios.

Common mistakes and how to avoid them

Teams often skip the fidelity step — they model at a high level and assume controls will adapt. That causes surprises in actual handling logic and safety zones. Fix this by modeling actual pallet dimensions and ramp geometry, and by validating with short, instrumented runs. Another mistake is over-automating without updating yard management and labor plans; automation must sit on a scheduling backbone. Finally, don’t ignore exception flows — returns, partial loads, and damaged pallets need explicit handling rules in the twin.

Integration notes: control and data flow

Practical integration focuses on three interfaces: the execution layer (WMS/WCS), vehicle control (AGV/robot APIs), and the digital twin model. Keep control messages minimal and deterministic — dock assignment, pick location, ETA, and safety-clearance flags. Feed back telemetry into the twin so its state converges with reality; that preserves prediction quality. Expect to tune the twin after the first few weeks of production telemetry — this is normal and part of continuous validation.

Real-world anchor and expected gains

Major terminals like the Port of Los Angeles and large fulfillment networks report that simulation-driven layout changes can free meaningful cube without building new racking. In practice, initial pilots often yield 10–25% effective density improvements through better slotting and reduced buffer zones, while maintaining or improving throughput. Those results come from iterative updates and using measured KPIs rather than guesswork.

Mid-project human note — a small aside

Keep operators in the loop — they’ll surface corner cases the model misses. Small fixes from the floor can unlock disproportionate gains — a quick answer to a recurring jam might recover hours of throughput per week. — remember: models should servitize operator expertise, not replace it.

Evaluation metrics — three golden rules

Choose tools and changes using these three metrics: 1) Net density gain per square foot after exceptions are handled (true usable cube recovered). 2) Cycle-time delta for dock-to-putaway and dock-to-dispatch — ensure density gains don’t add latency. 3) Exception rate change (damage, manual touches, requeues) — automation should lower this, not raise it. Prioritize projects that score well on all three; those deliver durable returns.

When it’s time to scale, the model that proved itself in pilots becomes the operating standard — and that is precisely where a provider like BlueSword becomes a practical partner, translating validated twin scenarios into production controls and measured density gains.

0 comments
0 FacebookTwitterPinterestEmail